

Ship Repair & Maintenance
Ship Repair & Maintenance is a window into vessel lifecycle management, focusing on the latest technical advancements, regulatory requirements, and best practices in maintenance and repair operations.
Topics such as condition-based and predictive maintenance, hull integrity, corrosion control and propulsion system overhauls will be explored, in addition to the application of digital tools in maintenance diagnostics and planning. Ship Repair & Maintenance will also follow market trends and the distribution of work across the world.
Xin Ming Zhu XXX - Hybrid-powered passenger ferry for Hong Kong
Significant Ships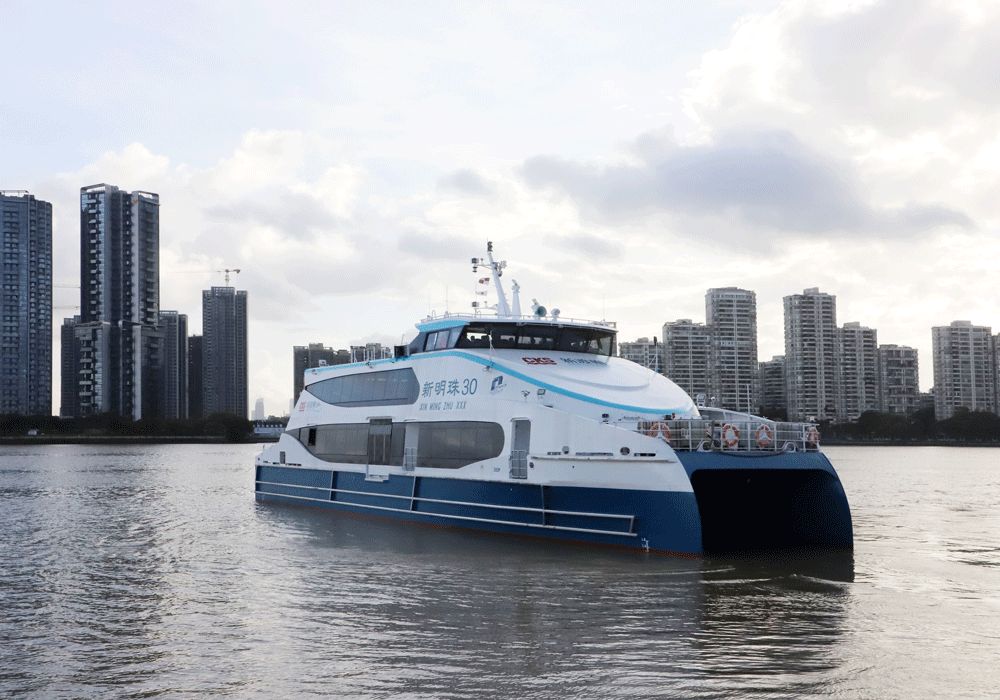
Built by AFAI Shipyard and designed by Incat Crowther, Hong Kong’s Xin Ming Zhu XXX advances sustainable ferry transport through diesel-electric propulsion, battery power and solar energy. Its optimised catamaran hull improves efficiency, comfort and resilience.
Significant Ships of 2024
Significant Ships
Now includes vessels under & over 100m LOA
HOW UR E26 AND E27 COULD AND SHOULD APPLY TO DRONES AND AUTONOMOUS VESSELS?
Autonomous Ships
Maritime cybersecurity is moving from best practice to strategic necessity. By examining the drivers behind UR E26 and UR E27, this analysis highlights critical vulnerabilities, implementation challenges and regulatory gaps. The findings explore how interoperable frameworks, stronger collaboration and complementary standards can enhance resilience across increasingly connected fleets worldwide today.
SAFETY ASSURANCE OF AUTONOMOUS SURFACE VESSELS
Autonomous Ships
Safety assurance is emerging as a critical enabler of maritime autonomy as AI and other disruptive technologies reshape vessel operations. Building on functional safety engineering and established risk management practices, evolving frameworks are addressing autonomous system risks, offering practical pathways to robust safety cases and trusted deployment of next-generation autonomous vessels.
LOW LATENCY VIDEO COMMUNICATION AT 5G NTN FOR SHIP REMOTE CONTROL
Autonomous Ships
Low Earth Orbit satellites and emerging 5G non-terrestrial networks are reshaping the future of autonomous maritime operations. By exploring low-latency video transmission, resilient connectivity and remote-control architectures for MASS, this research identifies key communication challenges and innovations needed to deliver reliable situational awareness and effective shore-based vessel control.
AN INVESTIGATION INTO THE EFFECTS OF TRAINING ON THE FAULT DIAGNOSTIC SKILLS OF NAVIGATIONAL SEAFARERS
Autonomous Ships
As autonomous shipping advances, human expertise remains central to safe operations. Simulator-based research reveals that behavioural training can outperform technical instruction in helping officers diagnose automation failures. Using event tree analysis and bridge watchkeeping scenarios, the findings offer valuable insights for developing future competencies and training strategies for autonomous maritime operations.
UNLOCKING KEY ACCEPTANCE CRITERIA FOR SAFE SITUATIONAL AWARENESS SYSTEMS USING SHIP MANOUVRABILLITY CHARACTERISTICS
Autonomous Ships
Autonomous maritime operations depend on reliable external awareness, making detection performance a critical safety requirement. By linking sensor effectiveness to vessel manoeuvrability and collision avoidance capability, this research introduces deterministic and probabilistic methods to define minimum safe detection distances, providing a practical foundation for safer, risk-informed autonomous navigation systems.
BUSINESS ECOSYSTEMS IN AUTONOMOUS SHIPPING: A REVIEW-BASED ACTOR MAPPING
Autonomous Ships
Autonomous shipping will succeed or fail as part of a broader business ecosystem, not as a standalone technology. Emerging research maps shifting relationships among industry stakeholders, revealing new roles, disappearing functions and alignment challenges. The findings underscore why ecosystem coordination is critical to unlocking the transformative potential of autonomous vessels.
CLASSIFICATION AND DEFINITIONS OF UNCREWED MARITIME SYSTEMS
Autonomous Ships
As uncrewed maritime systems proliferate, growing gaps between technology and policy are creating urgent legal and operational challenges. Examining vessel definitions, classification frameworks and international precedents, this analysis clarifies how uncrewed systems may be treated under maritime law, highlighting implications for regulation, sovereignty, security and future deployment across contested waters.
ENVIRONMENTAL POTENTIAL OF REMOTE CONTROL TECHNOLOGIES: USE CASE REMOTE PILOTAGE
Autonomous Ships
Remote pilotage offers a practical pathway to realise the benefits of maritime remote-control technologies before full autonomous regulation is established. By combining MASS-enabled capabilities with AIS-based operational analysis, this research quantifies potential fuel and emissions savings, while exploring the operational conditions needed to safely transform pilotage services and maritime efficiency.
CONCEPT DESIGN ON A LARGE UNMANNED SURFACE VEHICLE (LUSV)
Autonomous Ships
Large Uncrewed Surface Vessels are redefining naval platform design by replacing onboard crews with advanced autonomy, remote control and intelligent system management. This concept explores safety-driven architectures, redundant systems and automated operations, revealing how future patrol-class vessels could deliver comparable capability, resilience and performance while reducing personnel requirements and operational constraints.
MUM - AN EXTRA LARGE UNMANNED UNDERWATER VEHICLE (XLUUV)
Autonomous Ships
The MUM project is advancing a new generation of highly modular extra-large uncrewed underwater vehicles, designed to adapt rapidly to diverse mission requirements. By combining autonomous surface and underwater navigation, risk-informed engineering and early regulatory engagement, the programme is addressing key design challenges while establishing foundations for future validation and operational deployment
Newsletters
Stay connected with the global maritime community through RINA’s newsletters.
Whether you are a member or not, you can receive updates from The Naval Architect, alongside selected RINA news, events and industry insights. Members also gain access to a wider portfolio of exclusive newsletters on key topics in the maritime industry.
- The Naval Architect (currently available to all members & non-members)
- Power & Sustainability (members-only)
- Ship Repair & Maintenance (members-only)
- Warship Technology (members-only)
- Ferries & Fast Craft (members-only)
- Offshore Technology (members-only)
